Move Joints to A Target Angle
Function:
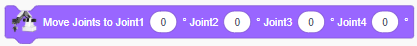
Description: Move robot to a target position
Parameter:
- Joint1: Set the angle of Joint 1
- Joint2: Set the angle of Joint 2
- Joint3: Set the angle of joint 3
- Joint4: Set the angle of joint 4
- Return: null
Function:
Description: Move robot to a target position
Parameter: